The autonomous driver for the buses cities already run.
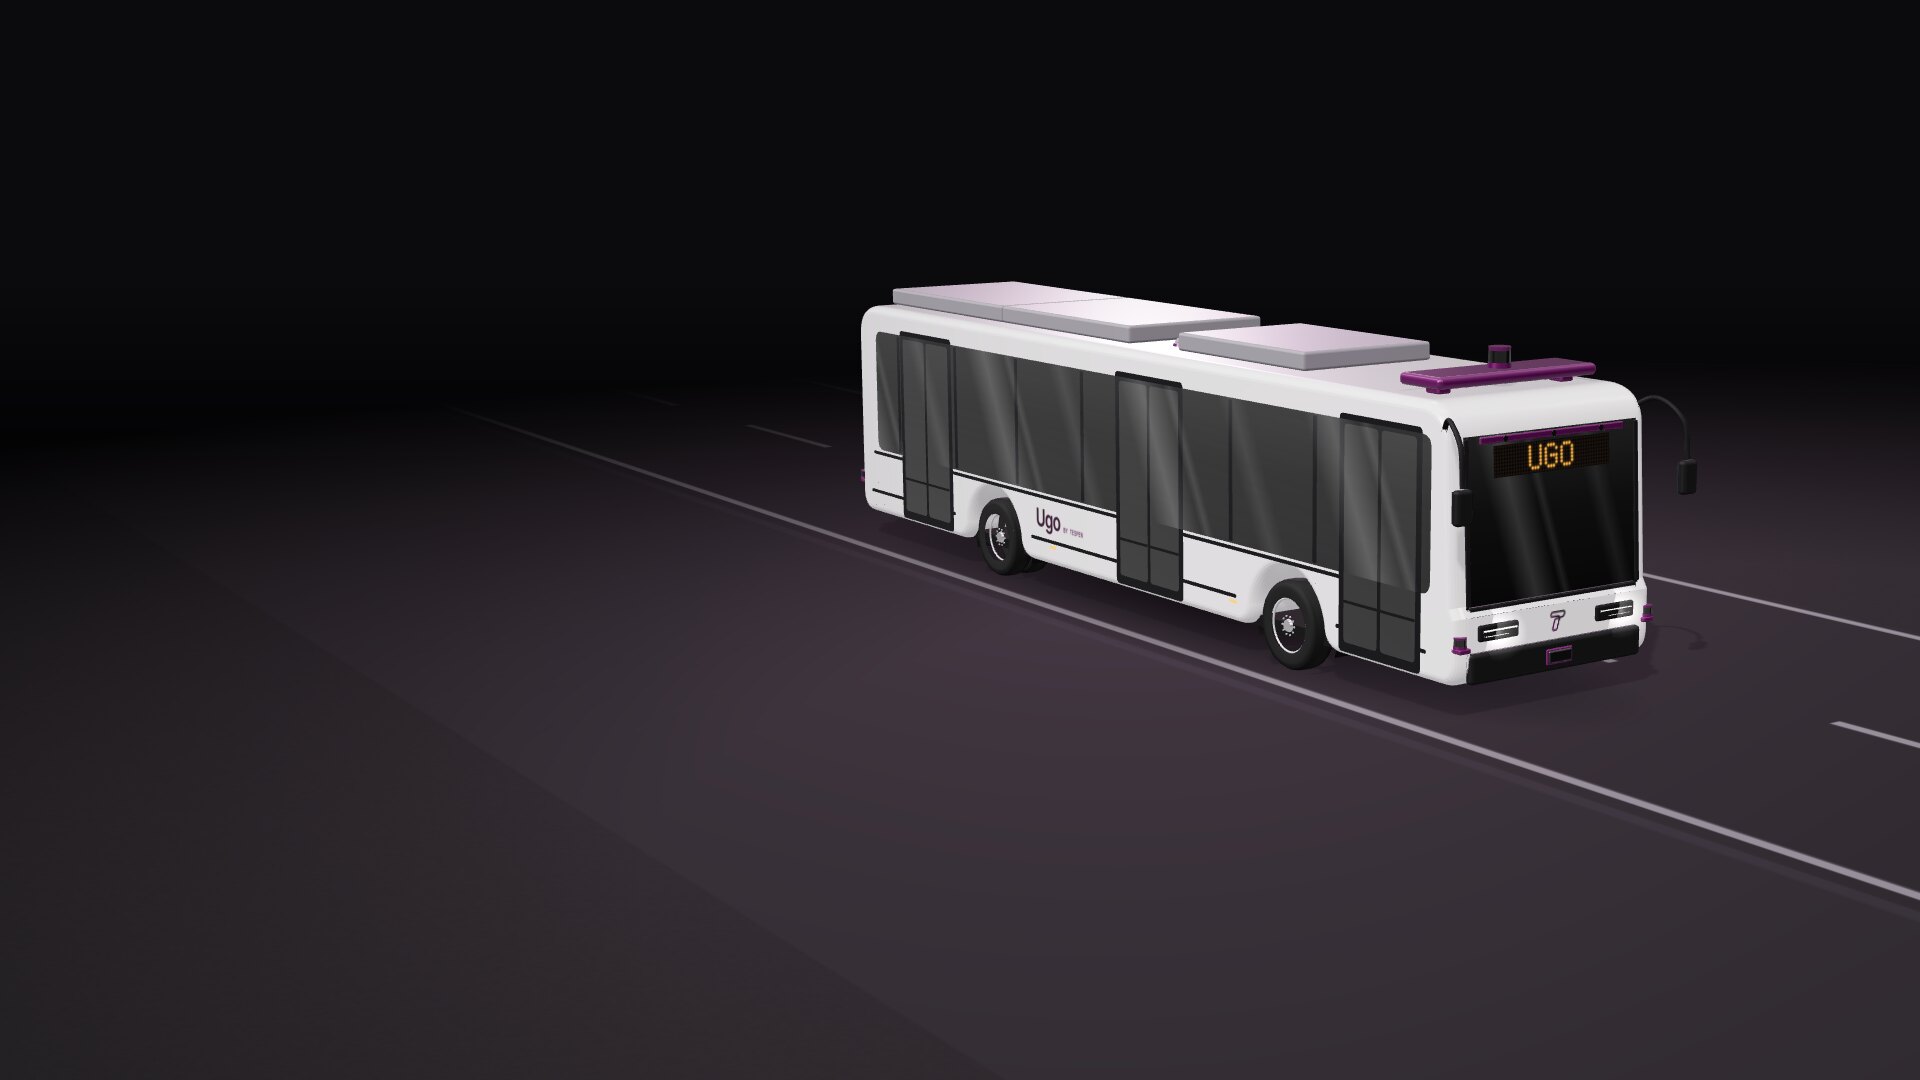
Ugo is driving software plus a retrofit kit for the city buses operators already own.
What Ugo sees.
LiDAR returns from the street, road users with their predicted motion, and the path the planner has chosen for the bus. Click the road to set a new goal.
Violet parts: the Ugo kit Drag to orbit Click the road to set a goal pose Illustrative, not vehicle data
We don’t need to make autonomy easy. We need to make the problem smaller.
A robotaxi has to go anywhere. A city bus runs the same route, stop after stop, all day, with a professional fleet behind it. That is the problem we chose: known routes, defined geography, repeatable operations. Validate one route, then expand.
Why buses firstWhere we are
Status · Autumn 2026in simulation
testing
System architecture defined, and first-route requirements set with European transit operators.
Developing the full software stack in simulation, on digital twins of real routes.
Hardware-in-the-loop, then closed course and supervised on-road testing. The full path